Overview
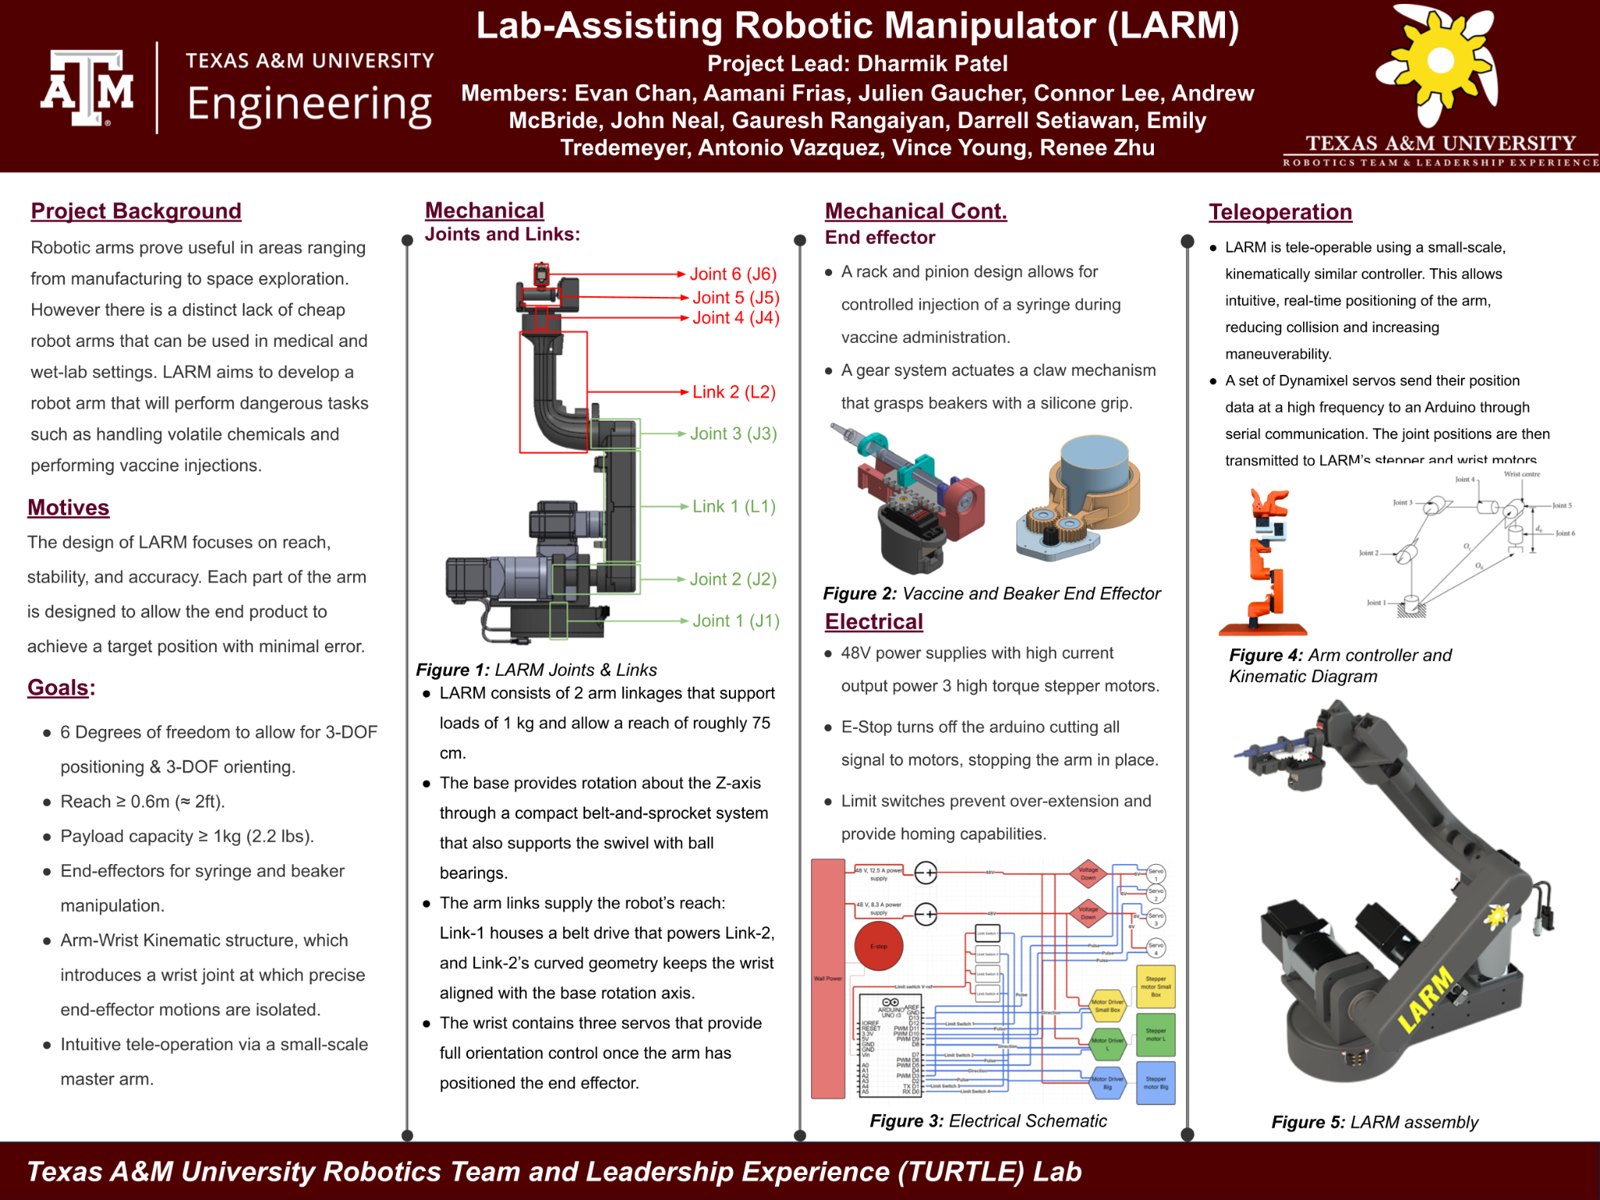
I worked on a multidisciplinary 13-person TURTLE R&D team to design a 6-DOF robotic arm for medical and wet lab applications. The goal was a teleoperated arm that can perform multiple lab tasks.
The arm is split into six subsystems: the base, L1, L2, the wrist, the end effector, and a mini-arm, a small-scale controller used to teleoperate it. I designed the L1 linkage and the wrist, and added a wiring route and limit-switch horn to L2.
L1 Linkage
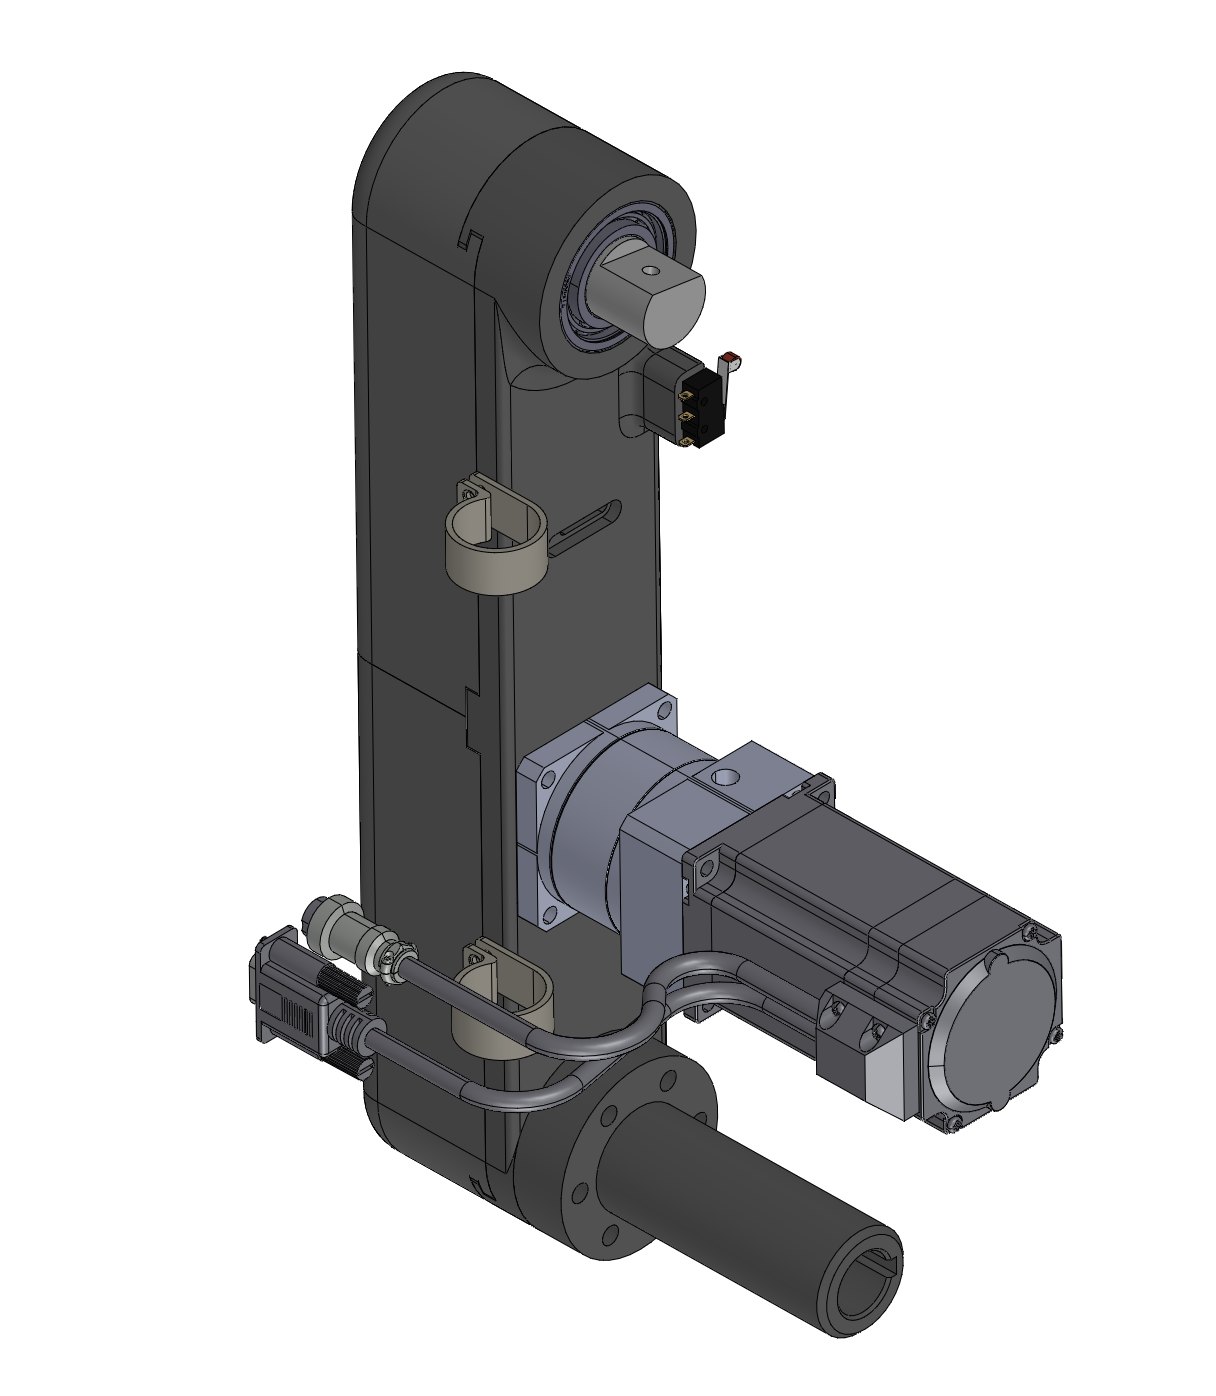
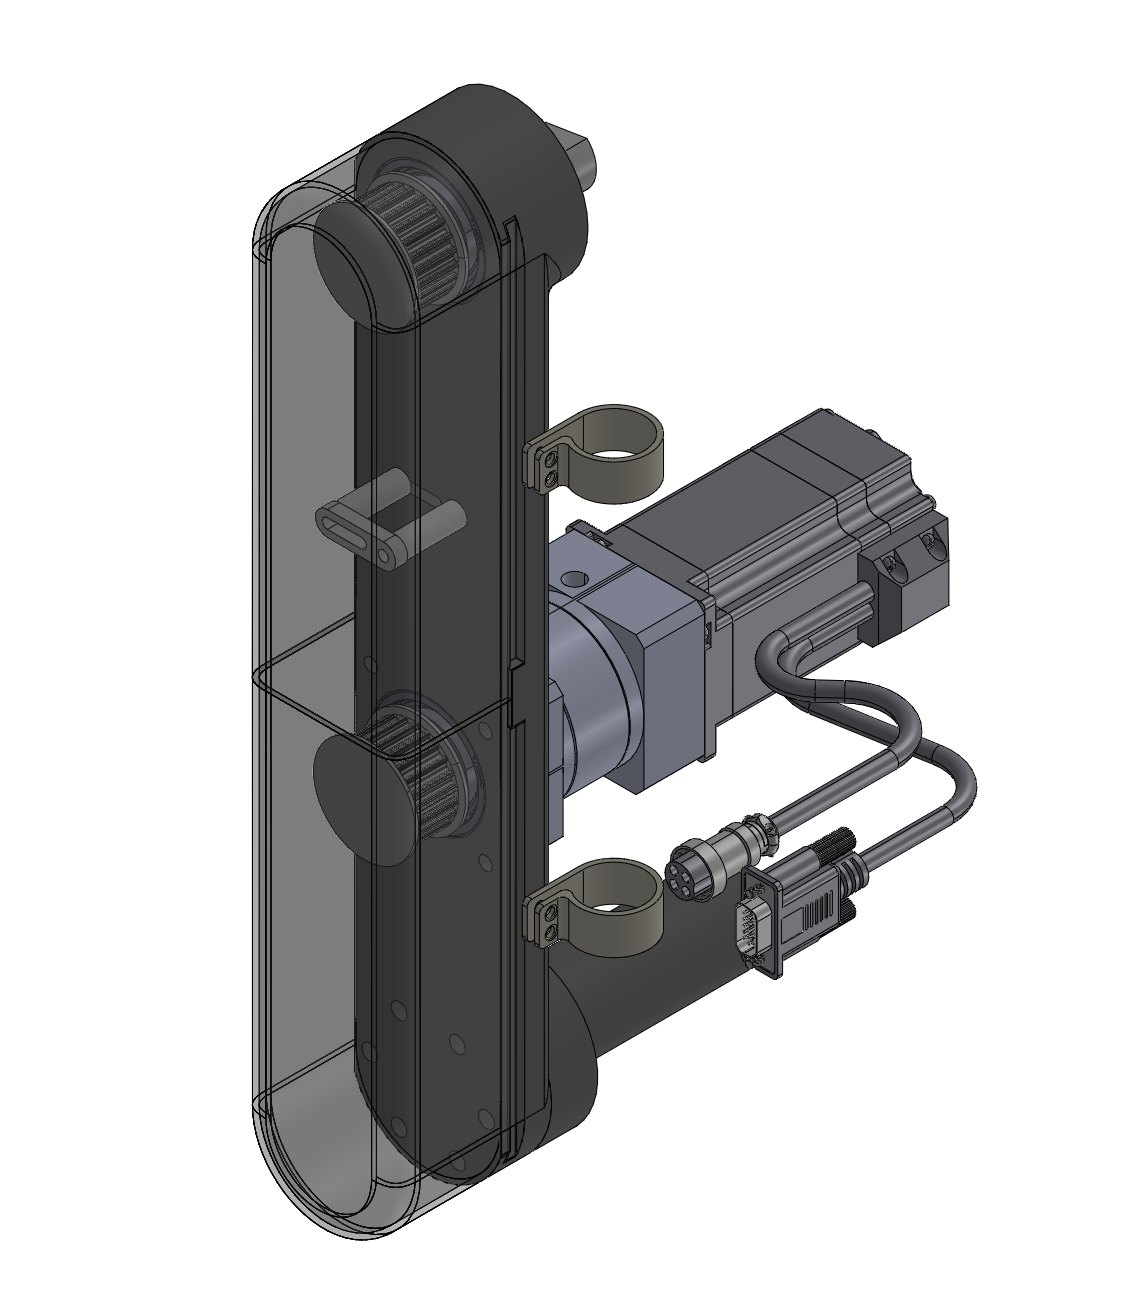
L1 is a 3D-printed PLA structure that houses the J3 drive: a belt-driven stepper and gearbox, with built-in belt tensioners and pulleys. Its lower shaft couples to J2 and its upper shaft to J3.
J3 is driven by a NEMA 23 stepper (2 N·m) through a 10:1 reduction, for 20 N·m of theoretical output torque.
L2 Linkage
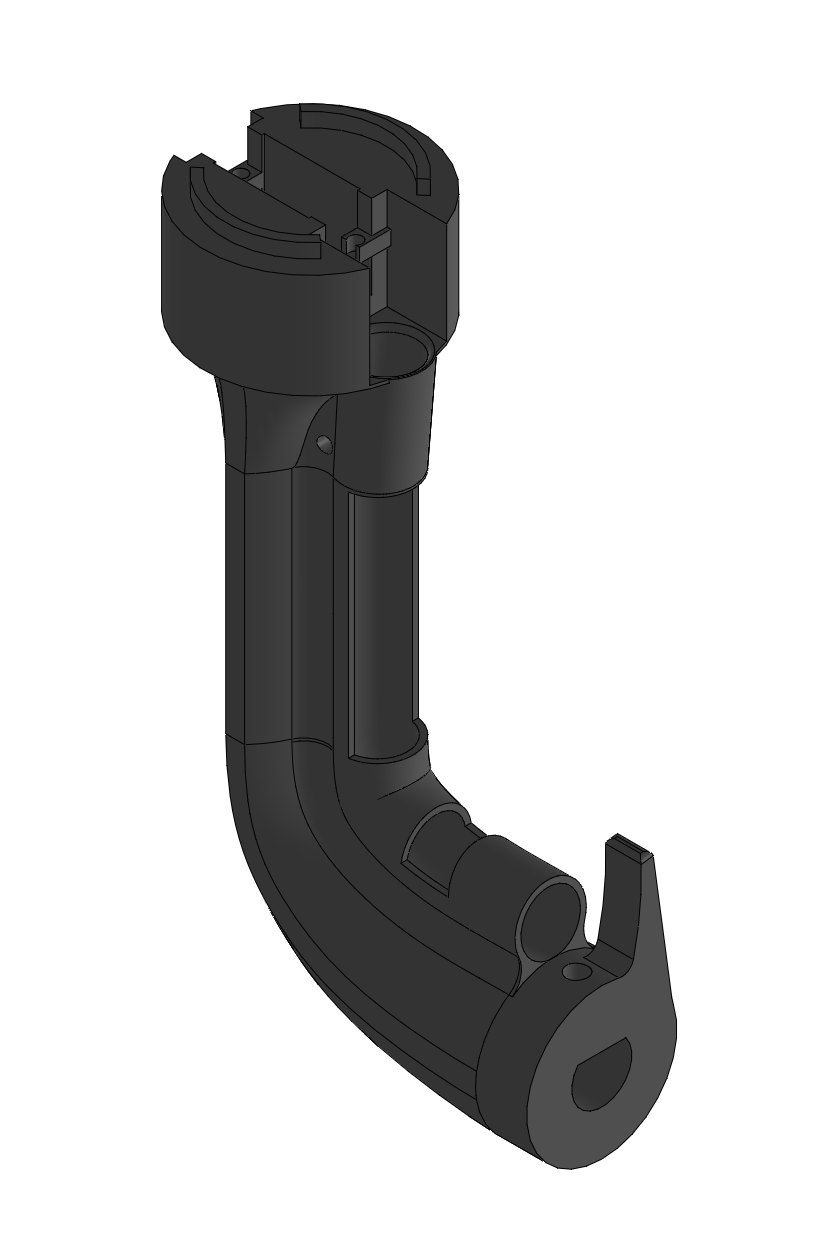
On L2, I added an internal channel to route wiring through the link, and a horn near the L1 joint for the limit switch to contact.
Wrist
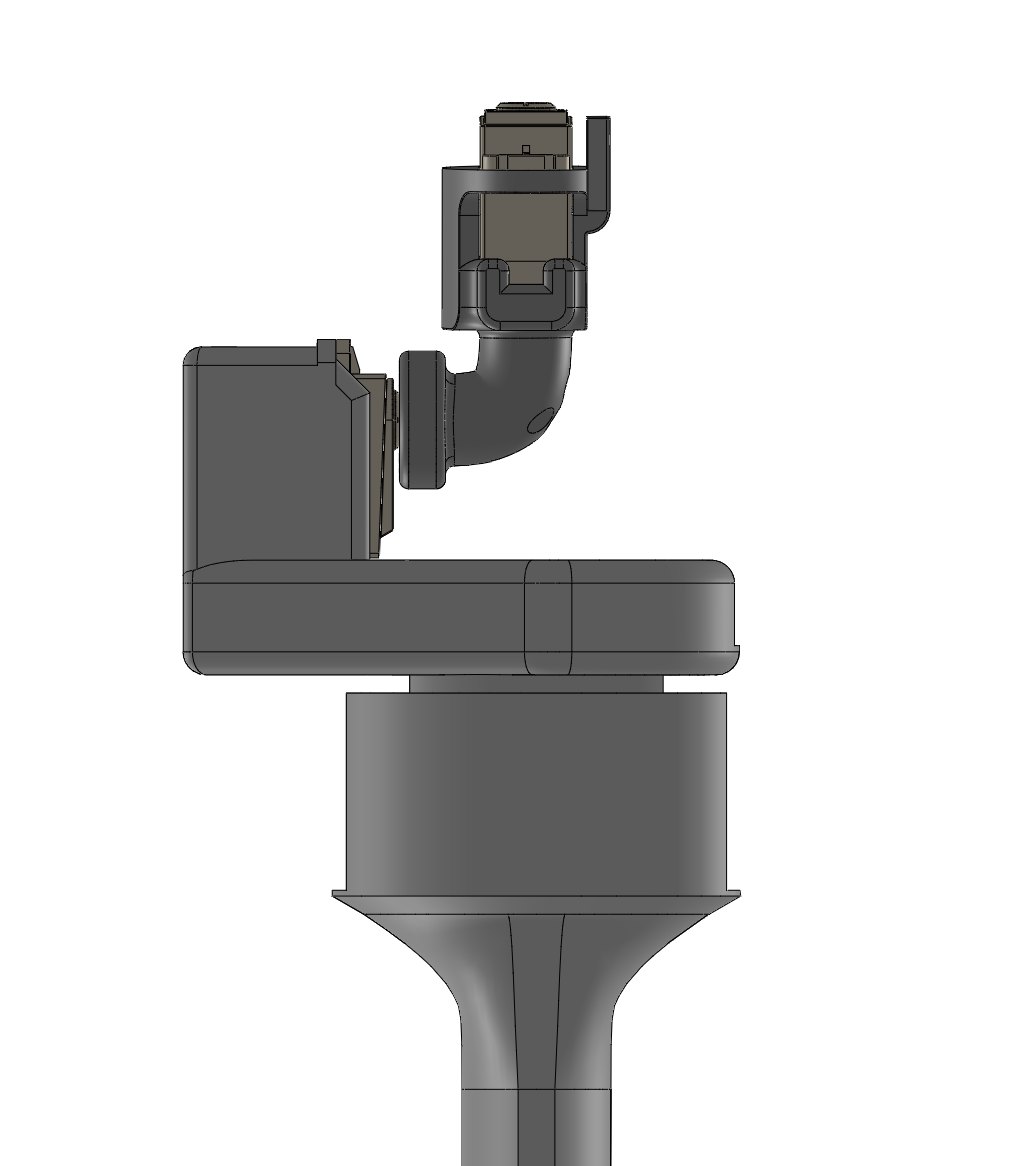
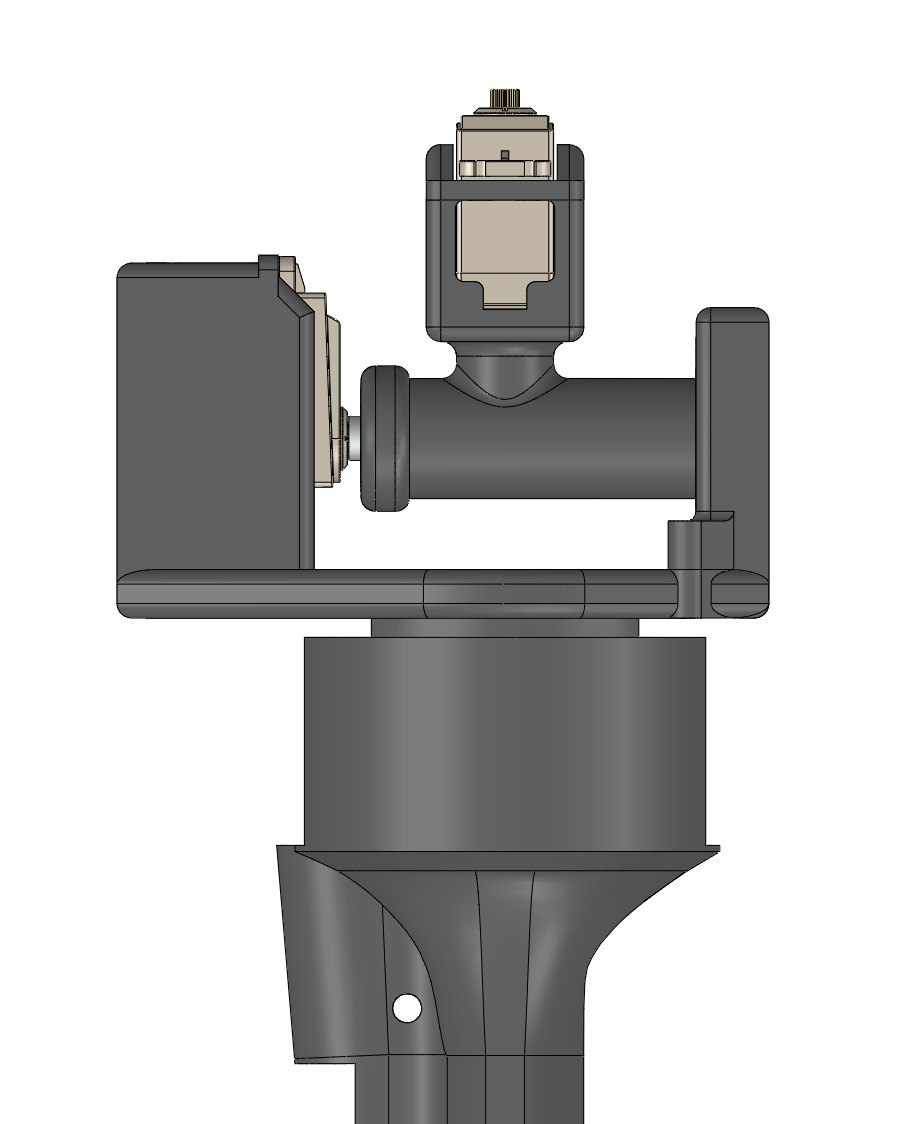
The wrist is a three-axis assembly driven by servos.
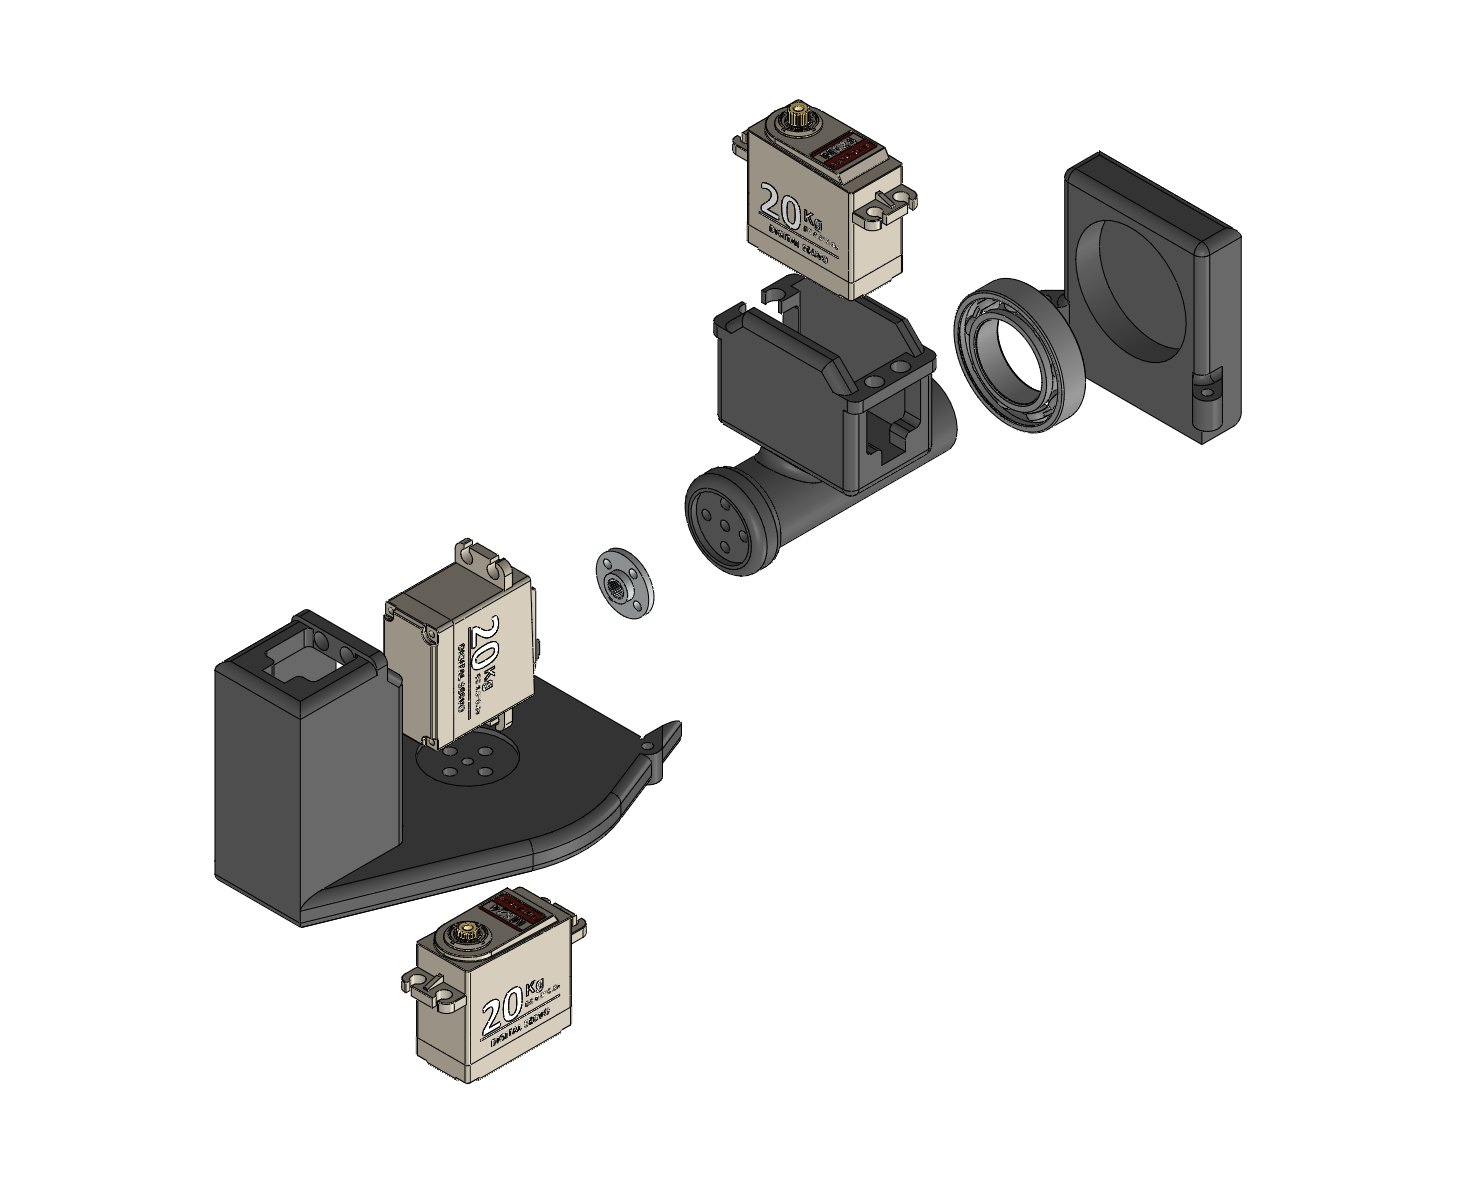
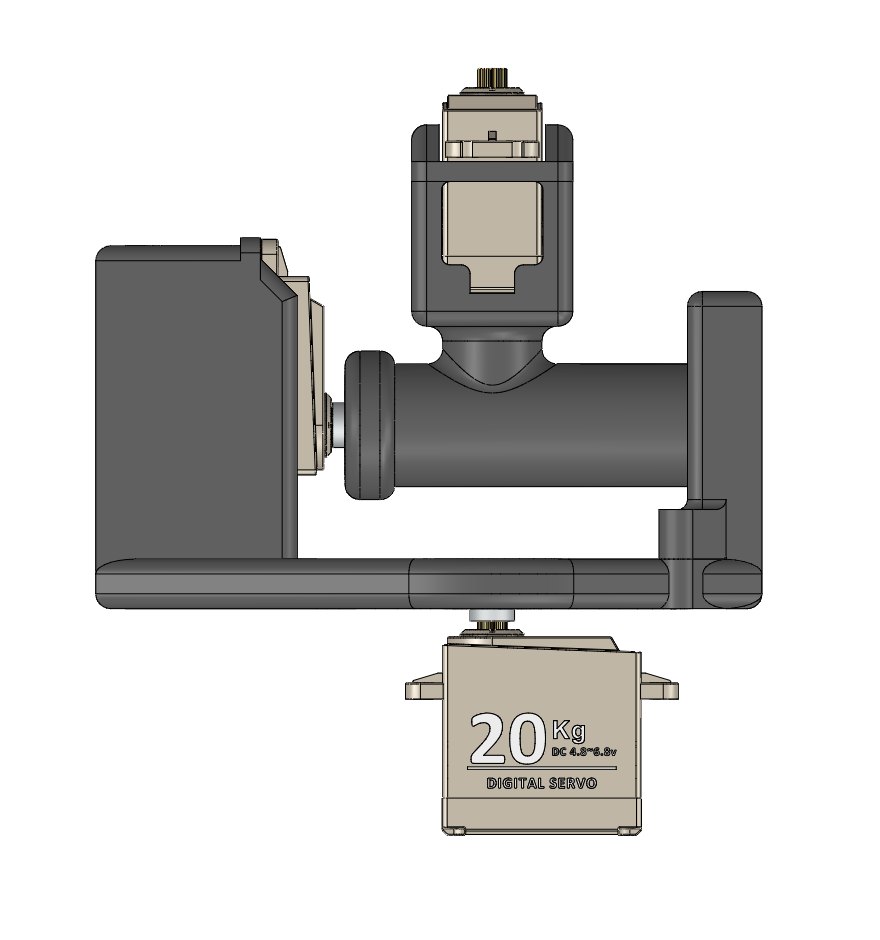
It went through two iterations. The first supported the wrist from a single side; the second supports it on both sides.