Overview
This actuator is the first step toward a desktop robot arm with custom actuators, joint encoders, and 3D-printed links. The goal is an actuator that runs continuously and transmits torque efficiently.
I chose a cycloidal drive for its low-backlash potential in precision robotics, and because the load is shared across many lobe contacts, which gives it a high contact area.
Design
The gearbox uses 13 lobes and 14 rollers for a 13:1 reduction. It is a dual-disc design: two cycloid discs run out of phase to balance the drive’s internal forces.
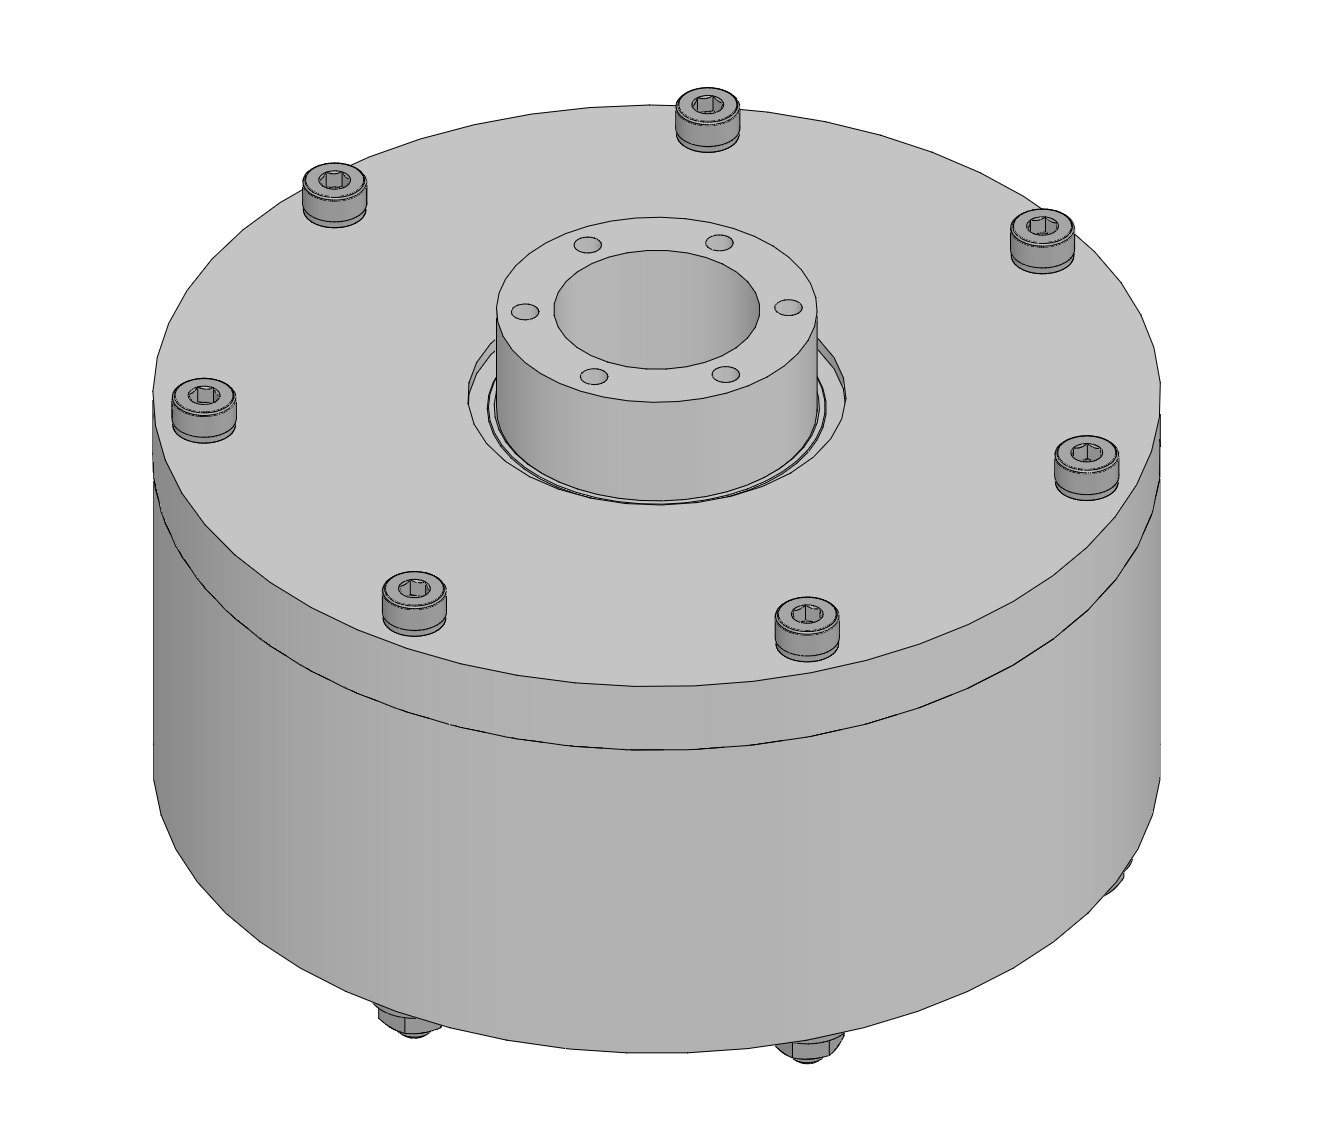
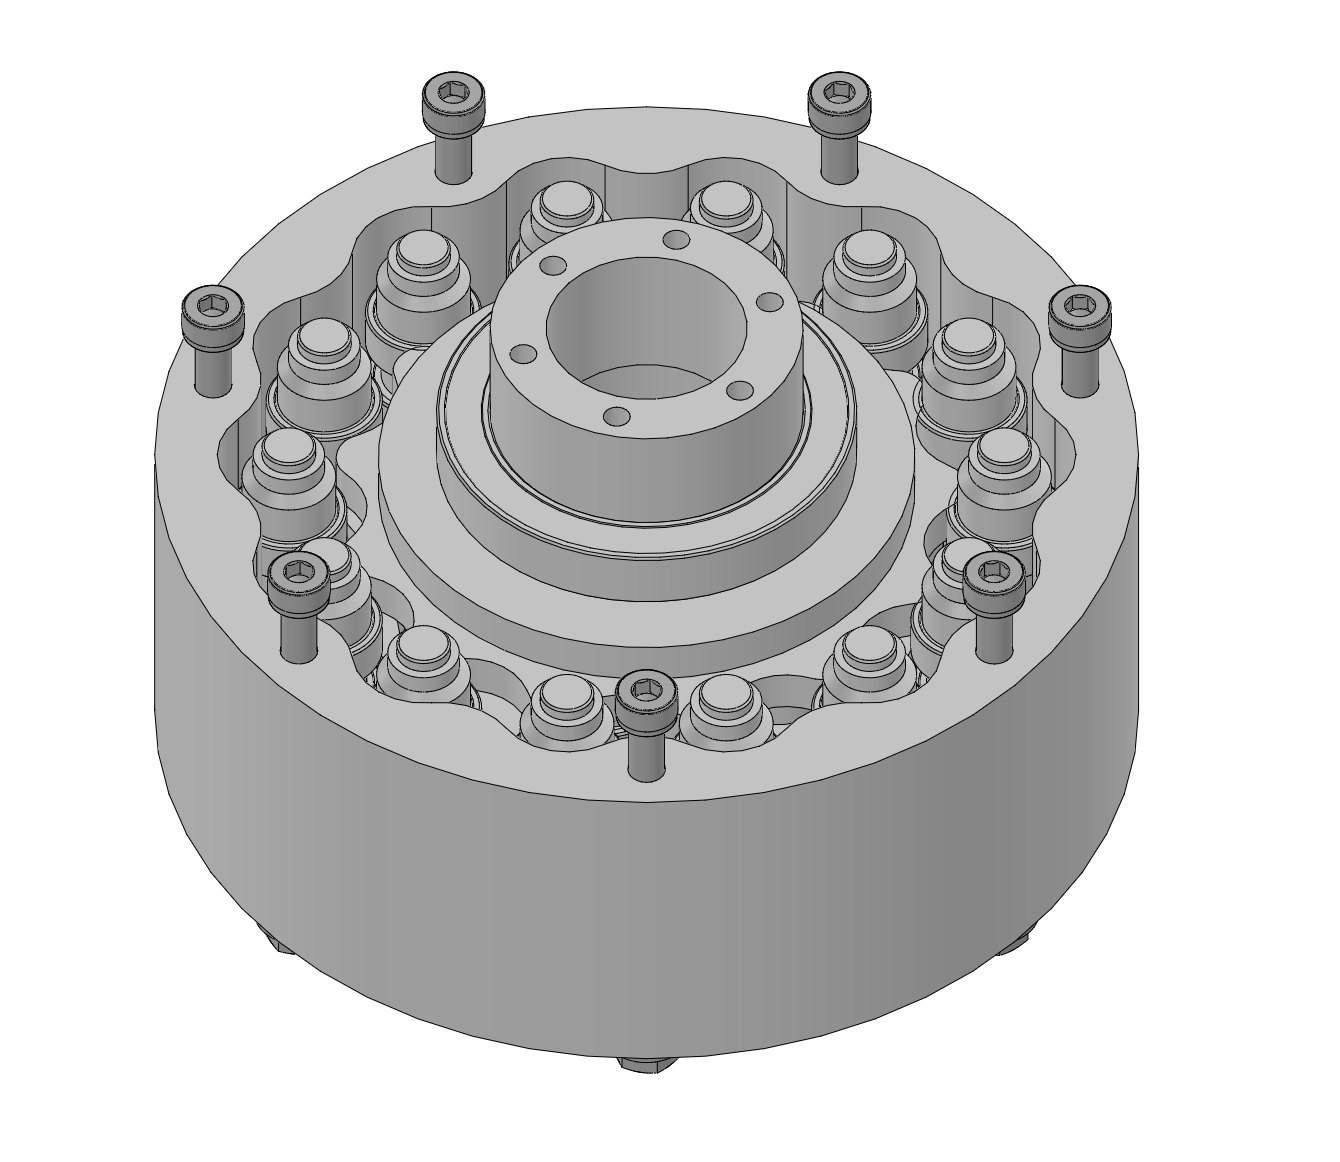
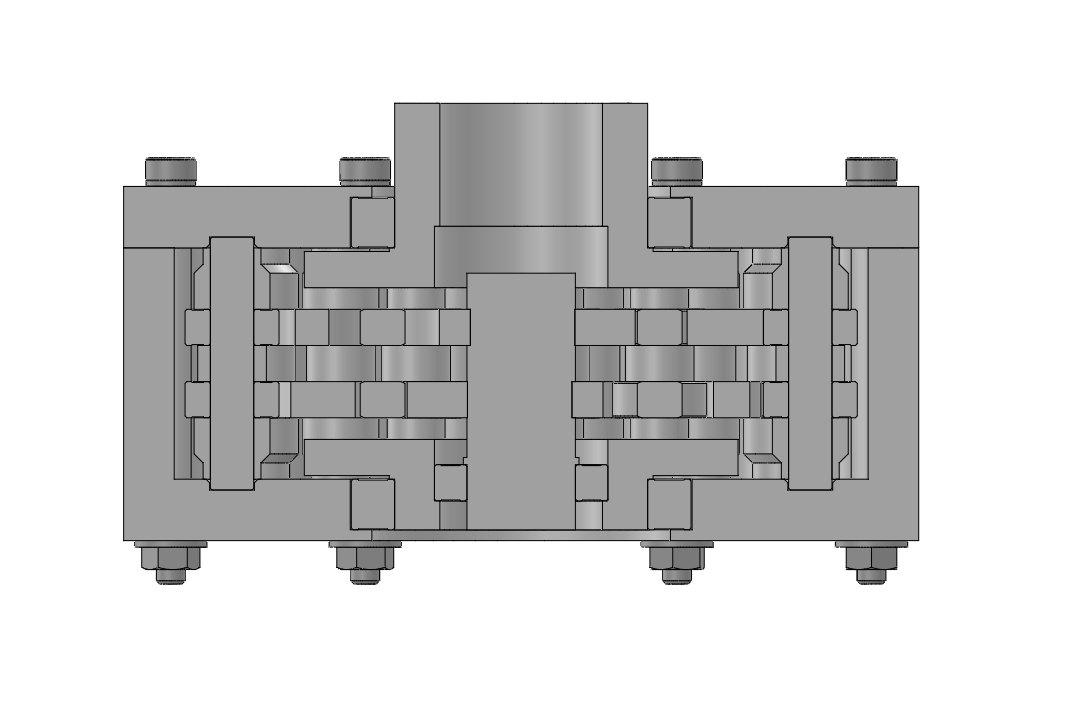
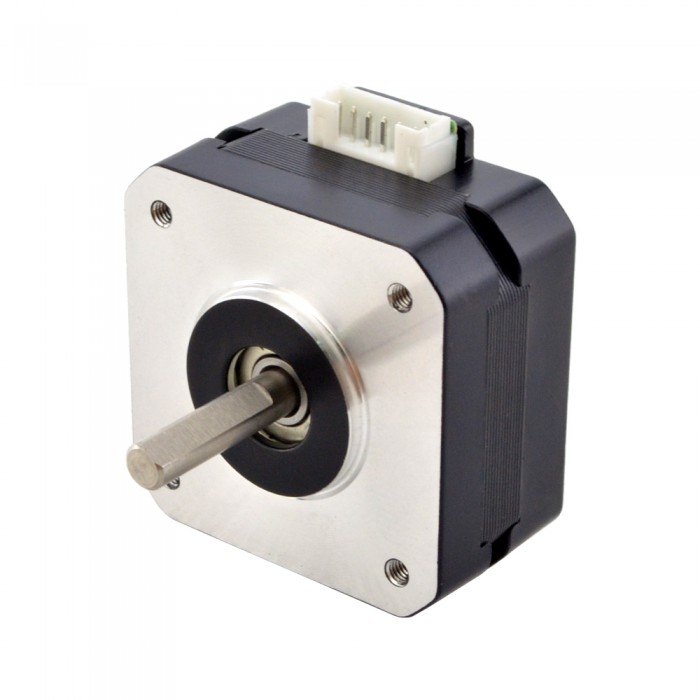
For testing, the input is a NEMA 17 stepper rated at 17 N·cm.
Test Results
1.33–1.77 N·m
Output torque: 60–80% of the 2.21 N·m theoretical output (17 N·cm × 13:1).
3+ hours
Continuous run with no failure; only slight wear on the cycloid discs.
Lever + probe
Torque from a force-probe reading on a lever arm fixed to the output shaft.
The torque benchmark is the motor’s stated rating multiplied by the reduction.